
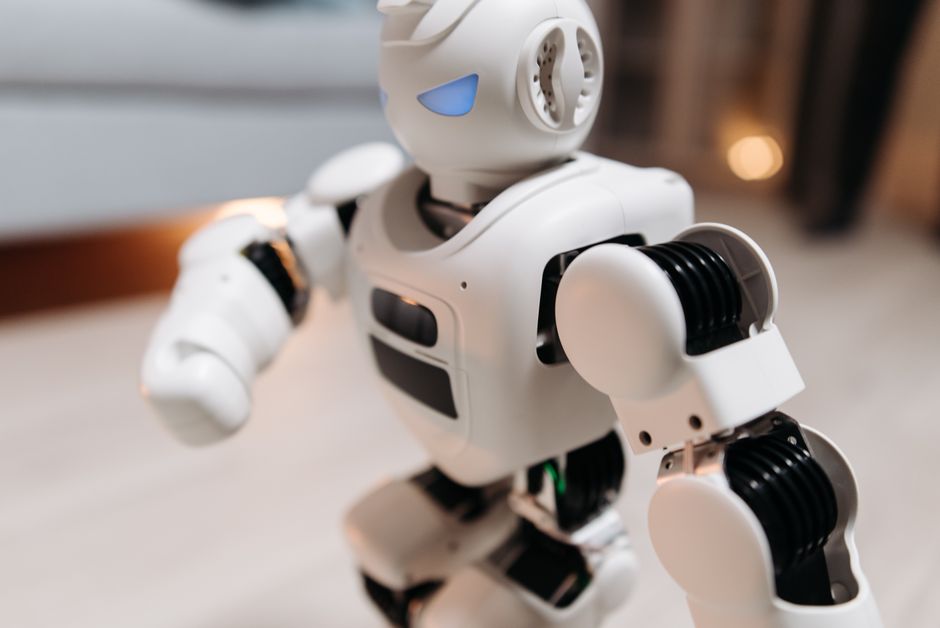
Building a walking robot at home is a real project you can finish on a kitchen table. It is not a science fiction fantasy. The simplest version is a small four-legged robot made from craft sticks, a few cheap servo motors, hot glue, and an Arduino board. You build the frame, attach four legs, wire the motors to a controller, upload a short program, and tune the leg motion until it shuffles forward. Total cost is usually under $50, and the first working walk often takes a weekend.
What Makes A Robot “Walk” Instead Of Roll?
Walking is a controlled fall. The robot lifts some legs, shifts its weight onto the others, and moves forward before it tips over. That cycle repeats over and over.
Wheeled robots are simpler because a wheel only spins one way. A walking robot has to coordinate several legs at once. Each leg has to lift, swing forward, plant, and push back. If the timing is off, the robot falls or drags a foot.
For a home build, the most forgiving design is a static walker. That means the robot always keeps enough feet on the ground to stay balanced while the other legs move. It looks slow and deliberate, but it does not fall over. Dynamic walkers, which balance on the move like a human, are much harder and usually need sensors and fast control loops.
Start with static. Get one leg moving correctly. Then add the rest.
What Parts Do You Need To Make A Walking Robot At Home?
You need a frame, four or more motors, a controller, a power source, and a way to connect it all. Nothing here requires soldering if you choose the right parts.
- Servo motors: Four small hobby servos (often called SG90 or MG90S) are enough for a light four-legged robot. Servos move to a specific angle, which makes leg positioning predictable.
- Microcontroller: An Arduino Uno or a similar beginner board. It sends the angle commands to the servos.
- Frame material: Craft sticks, thin plywood, or 3D-printed parts. Light is better. Heavy frames overload small servos.
- Power: A battery pack that matches your servos. Four AA batteries or a small rechargeable pack works for most starter builds.
- Connections: Jumper wires, a breadboard, and hot glue or small screws.
- Tools: A glue gun, scissors or a small saw, and a computer to upload code.
One detail that trips up beginners: small servos draw more current than an Arduino can safely supply. Power the servos from a separate battery pack and connect only the signal wires to the board. Sharing one power source often causes the board to reset every time the legs move.
How Do You Build The Frame And Legs?
Build a flat body first, then attach legs at the four corners. Keep the body as light as you can.
Cut two matching rectangles of craft stick or plywood and glue them into a single stiff plate. A floppy body twists under load and makes the robot walk in circles.
For each leg, you need two joints to get a natural step: one at the hip that swings the leg forward and back, and one at the knee that lifts the foot. That means two servos per leg. Four legs with two joints each is eight servos, which is a lot for a first build.
A simpler option is one servo per leg. The servo rotates a bent leg piece, and the shape of that bend does the lifting and stepping in a single motion. It is less precise, but it works and it is far easier to debug.
Mount each servo so its rotating arm points outward from the body. Glue a leg piece to the arm. Make all four legs identical. If one leg is a different length, the robot will lean and stall.
How Do You Wire And Program The Robot To Walk?
Wiring is straightforward: each servo has three wires for power, ground, and signal. The signal wire goes to a numbered pin on the Arduino.
Group the power and ground wires from all servos to the separate battery pack. Run the signal wires to four different pins on the board. Double-check that power and ground never cross before you plug in the battery.
The program is where the walking actually happens. You are not writing complex math. You are telling each servo what angle to hold, and when.
A basic walking cycle has four steps:
- Lift the front-left leg and swing it forward.
- Plant it and shift weight onto it.
- Lift the opposite back leg and swing it forward.
- Repeat with the remaining two legs in the same diagonal pattern.
This diagonal pattern is called a trot, and it is the easiest gait to get working. You write the angles for each leg as a list, then loop through the list with short pauses between each position. Most starter code is under 50 lines.
Upload the program and watch. The legs will move. Whether the robot walks is a separate question.
Why Does My Robot Fall Over Or Drag Its Feet?
Almost every first build fails in one of a few predictable ways. The fixes are usually small adjustments, not a rebuild.
If the robot tips forward, its center of gravity is too high or too far forward. Move the battery pack lower and toward the middle of the body. Weight near the floor is stable weight.
If a leg drags, the lift angle is too small. Increase how far the knee servo rotates during the lift phase. The foot needs to clear the ground before it swings forward.
If the robot spins instead of walking straight, the legs are not symmetrical. Measure them again. Even a few millimeters of difference shows up as a curve.
If the servos twitch or the board resets, the power supply is the problem. Small servos can briefly pull more current than a shared supply provides. Give the servos their own battery.
If the motion looks jerky, your pauses between positions are too short. Servos need time to reach each angle. Slower often looks better and walks more reliably.
How Long Does It Take And What Does It Cost?
A basic four-legged walker takes most beginners a weekend to assemble and a few more evenings to tune. Budget around $30 to $50 for parts if you are buying everything new.
The building is the fast part. The tuning is where the time goes. Expect to run the robot, watch it fail, adjust one angle, and run it again many times. That loop is normal. It is also the part where you actually learn how walking machines work.
If you want a faster path, robot kits that include a frame, servos, and sample code exist for roughly the same price. They remove the frame-building step but not the tuning step. Either way, you will spend time adjusting leg angles.
Once a four-legged walker works, the natural next step is a two-legged robot. Be aware that bipedal walking is a genuinely harder problem. A two-legged robot has to actively balance with every step, which usually means adding sensors and a much faster control loop. Many hobbyists find that a four-legged robot is satisfying enough on its own.
Frequently Asked Questions
Can I build a walking robot without any coding experience?
Yes, if you start with a kit or copy a beginner program and adjust the numbers. You do not need to write code from scratch, but you will need to change values and re-upload the program to tune the walk.
How many servos does a simple walking robot need?
A basic four-legged robot can work with four servos, one per leg, using a bent leg shape to handle the lift and step. Adding a second joint per leg improves the motion but doubles the servo count and the wiring.
Why does my robot reset every time the legs move?
The servos are drawing more current than the Arduino can supply, which causes a voltage drop. Power the servos from a separate battery pack and connect only the signal wires to the board.
Is a two-legged walking robot harder to build than a four-legged one?
Yes, considerably. A four-legged robot can stay balanced with three feet down, but a two-legged robot has to actively balance with every step and usually needs sensors and faster control.
